
Varied products
Texture, shape and fragility: each preparation calls for a different approach to handling.
Robotics & culinary craft
We are developing robots to support kitchen teams with their repetitive tasks.
Explore applicationsDiscuss your workflow01 / Inside the kitchen
Pick, portion, place, repeat. We start with these everyday tasks to explore robotic assistance shaped around the way kitchen teams work.
Texture, shape and fragility: each preparation calls for a different approach to handling.
Hygiene, cleaning, available space and product changeovers are all part of the problem to solve.
Replenishment, quality checks and handling exceptions remain central to every conversation about automation.
02 / Applications
Development opportunities to explore with professionals, shaped by their products, constraints and ways of working.
01Proposed application
Pick and place the elements of a meal into a tray or container. Explore a sequence of movements suited to different compositions and ingredients.
Arrangement · Product variety · Handling
Two robotic arms illustrate picking and placing food into a tray. This is an animation, with no performance measurement. Illustration of an intended workflow. Displayed values are not measured results. Silent film.
02Proposed application
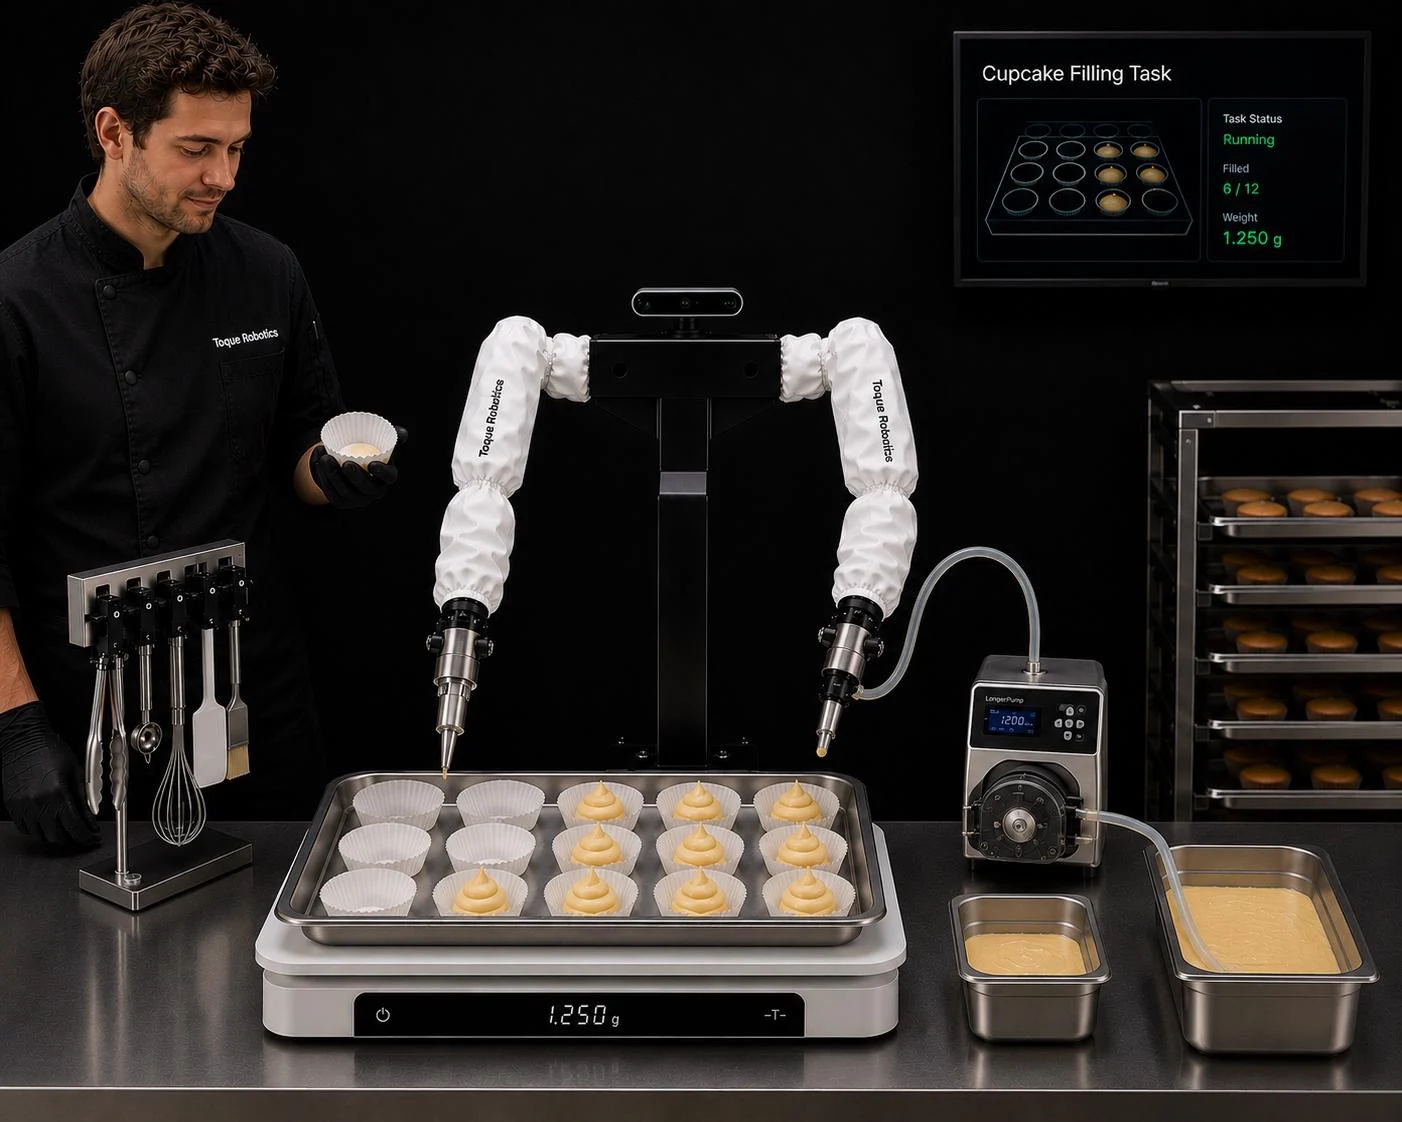
Portion a preparation and fill a container. Explore control of the deposited quantity and how the gesture fits into the packaging workflow.
Textures · Dosing · Container types
A robot illustrates depositing portions into moulds. This scene does not demonstrate a complete packaging process. Illustration of an intended workflow. Displayed values are not measured results. Silent film.
03Proposed application
Allocate products according to the references, quantities and destinations in an order. A separate development opportunity from assembling a meal.
Identification · Counting · Completeness
Proposed application
Cake decoration also expresses our vision: exploring how to repeat a gesture while preserving the culinary intention.
An animated robot writes the word Toque on a cake using a piping bag. The path and displayed data are illustrative. Illustration of an intended workflow. Displayed values are not measured results. Silent film.
03 / Our technology approach
Our development direction brings together perception, manipulation and learning from demonstrations. The aim: connect human expertise with the constraints of robotic movement.
A person illustrates a movement with a utensil, then a robot illustrates its reproduction. Trajectories and graphs are conceptual and do not establish validated autonomous learning. Illustration of an intended workflow. Displayed values are not measured results. Silent film.
Identify products, tools and their position in the workspace.
Adapt movement and interaction to ingredients and utensils.
Explore how a skill can be transferred through human demonstrations.
04 / Toque Robotics
We are building Toque Robotics around a conviction: culinary robotics should start with the real work of kitchen teams. Our ambition is to support repetitive tasks while preserving the role of human expertise.
Understand the workflow. Define the constraints. Move forward with professionals.
05 / Build what comes next
Together, we can identify a task, assess its constraints and explore a focused pilot.
Contact details coming soon.